

Magic-W0: A Structured World–Action Foundation Model for Physical Intelligence
Magic-Lab Team · Magiclab Robotics Inc.
Abstract
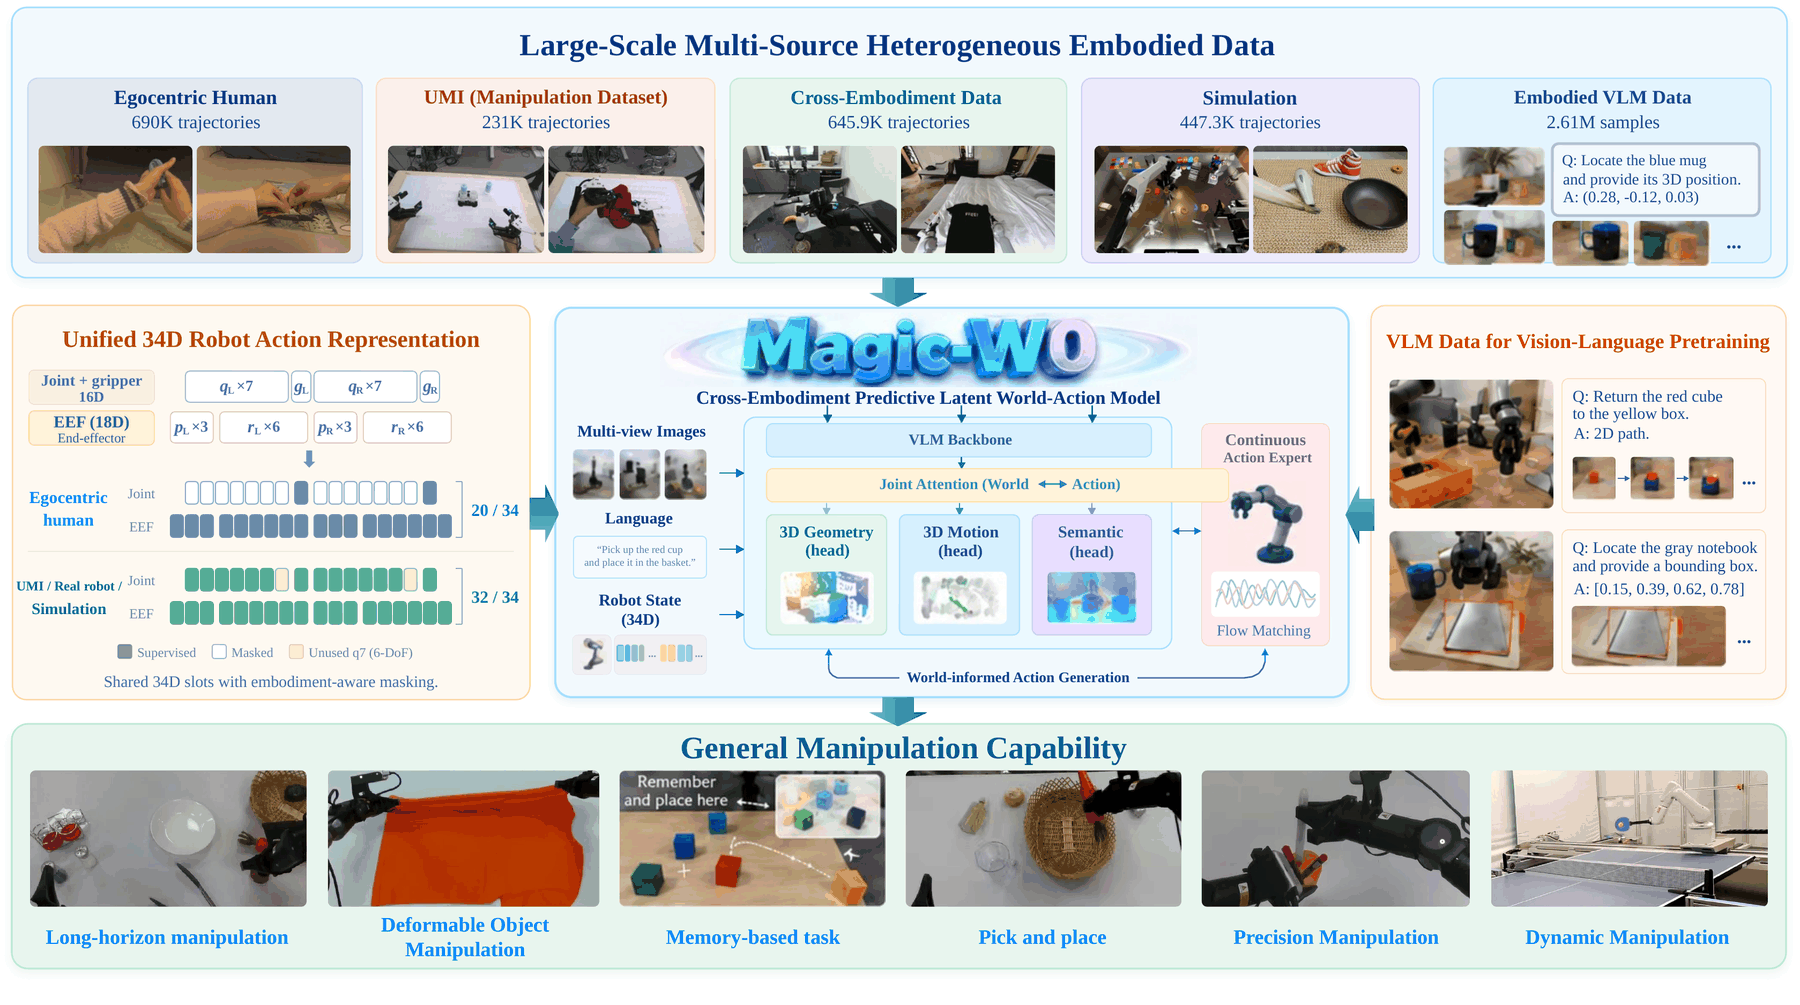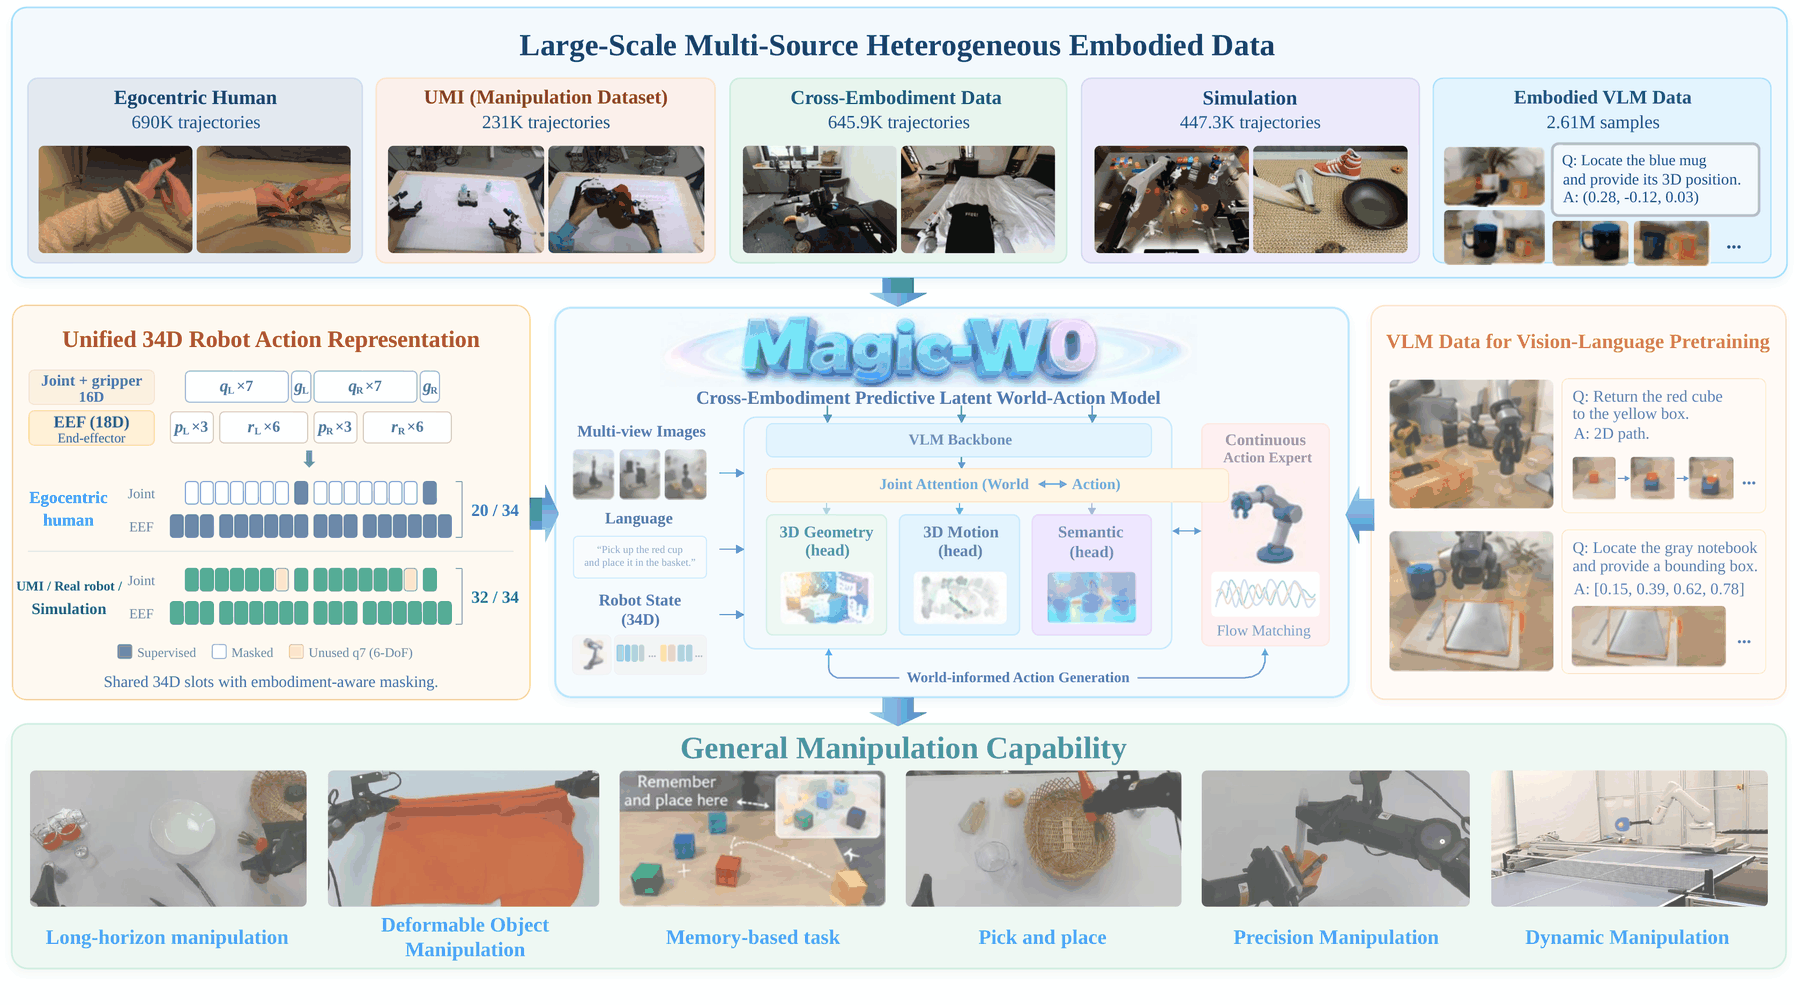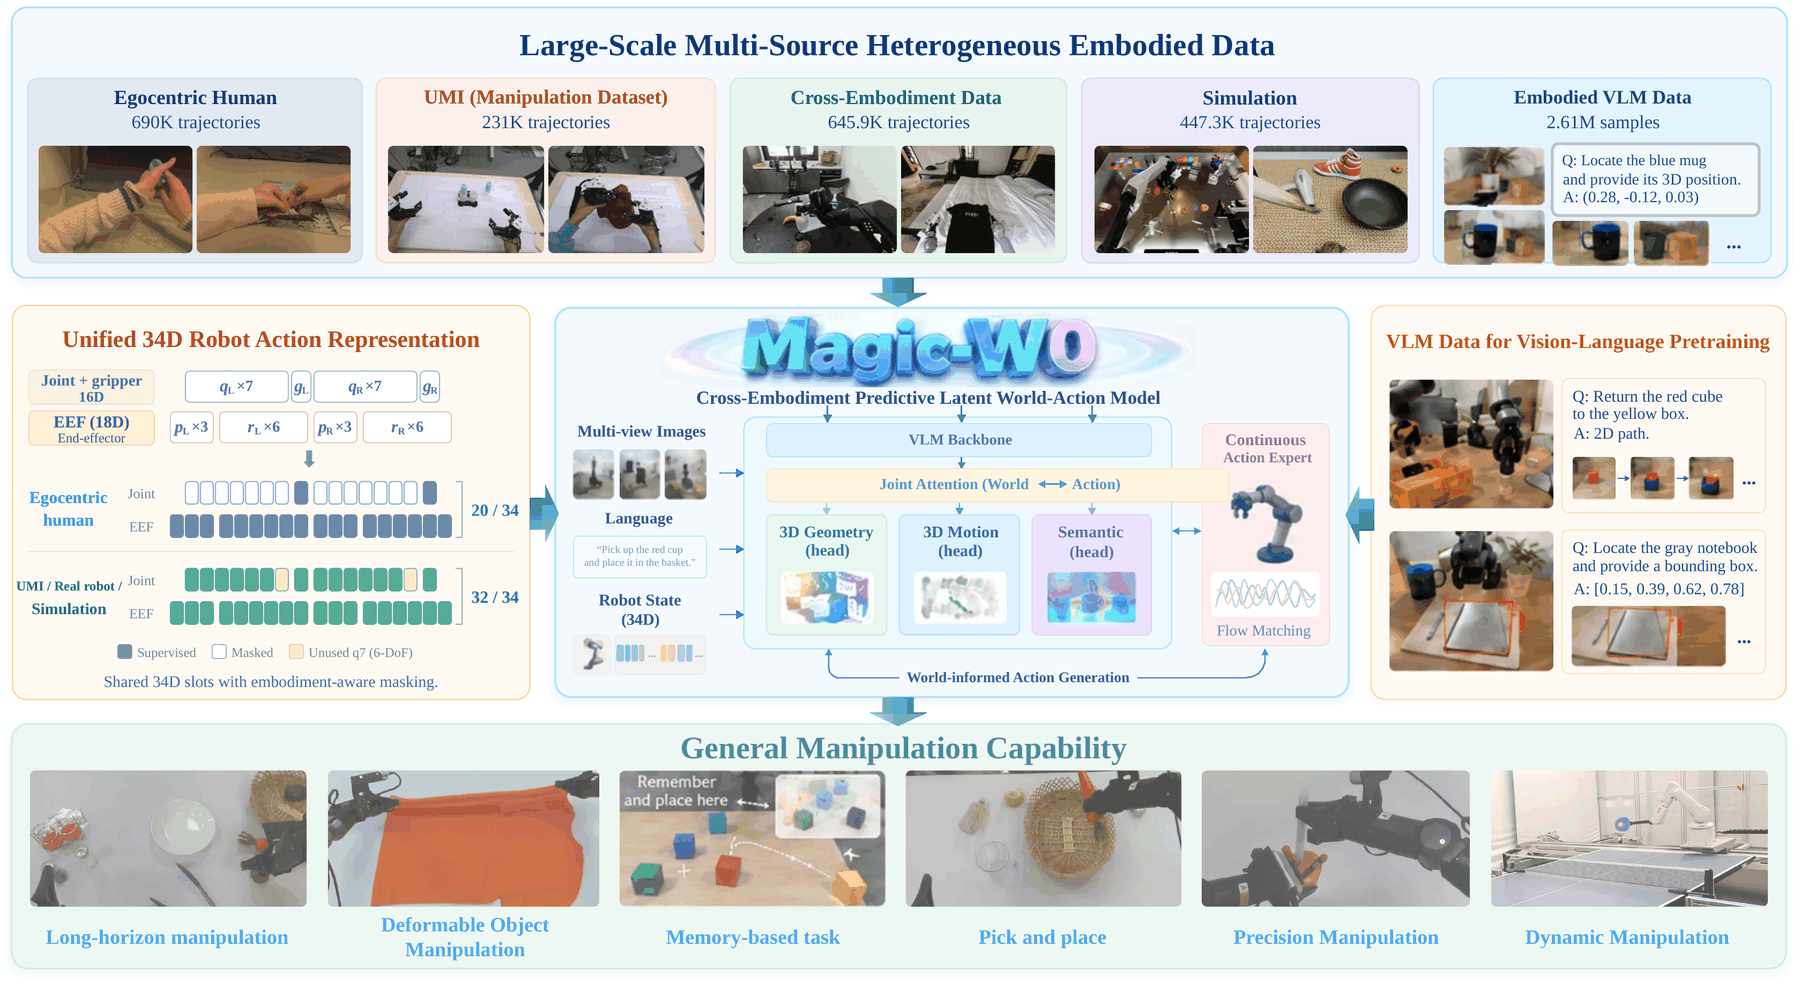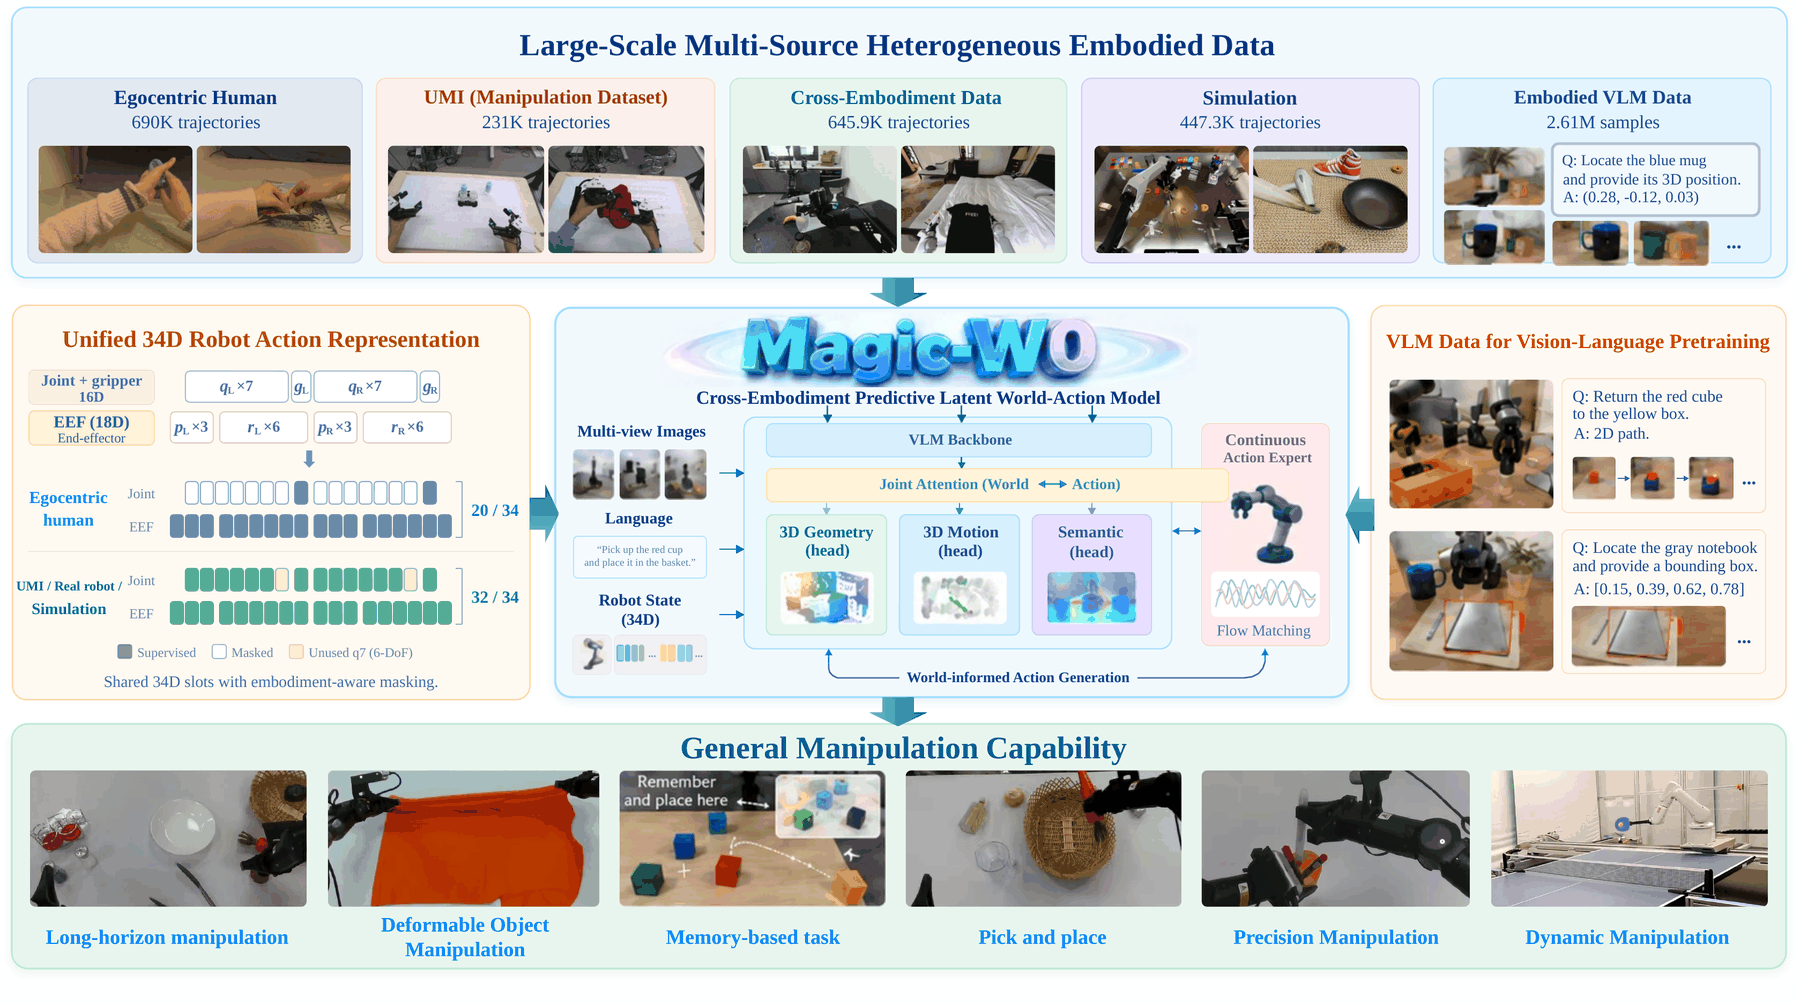
Magic-W0 jointly learns structured world transitions and continuous robot actions from diverse embodied experience. By coupling geometry, motion, and future semantics with action generation, it connects physical world modeling with robotic manipulation.
Key Features
- World–action modeling: jointly learn geometry, motion, future semantics, and continuous actions.
- Cross-embodiment learning: combine human, UMI, real-robot, and simulation experience.
- Teacher-free inference: use world-model supervision during training without running teachers at deployment.
Model Weights
This repository hosts Magic-W0 model weights and third-party model assets. Training and inference code and instructions are maintained in the GitHub repository.
Pretrained policy weights, RoboDojo SFT weights, and third-party training resources are now available:
| Repository path | Purpose |
|---|---|
pretrain_models/magic_w0_pretrain.pt |
Pretrained Magic-W0 checkpoint for downstream fine-tuning. |
robodojo_sft_models/magic_w0_robodojo.pt |
RoboDojo fine-tuned policy for evaluation and inference. |
third_party_models/ |
DINOv3 ViT-L/16, Track4World, Depth Anything 3, and ConvNeXt-Tiny resources for world-supervised training. |
Download
Download only the resources you need. The commands below preserve the repository
directory structure under checkpoints/:
python -m pip install -U huggingface_hub
# Pretraining checkpoint for downstream fine-tuning
hf download XuhuaX/Magic-W0 --include 'pretrain_models/*' --local-dir checkpoints
# RoboDojo policy for evaluation
hf download XuhuaX/Magic-W0 --include 'robodojo_sft_models/*' --local-dir checkpoints
# Teacher/backbone resources for training
hf download XuhuaX/Magic-W0 --include 'third_party_models/*' --local-dir checkpoints
Repository Layout
Magic-W0/
  pretrain_models/magic_w0_pretrain.pt
  robodojo_sft_models/magic_w0_robodojo.pt
  third_party_models/
    track4world_da3.pth
    convnext_tiny-983f1562.pth
    dinov3-vitl16-pretrain-lvd1689m/
    DA3NESTED-GIANT-LARGE-1.1/
    LICENSES/
License
Magic-W0 is released under the MIT license. Third-party assets retain their
upstream licenses; consult the third-party README,
licenses,
and original metadata under third_party_models/. The project's MIT license
does not replace those terms.